Embien's CANopen protocol guide introduces CANopen's object dictionary and device profile model generally, without covering the specific device profile that accounts for most of why engineers reach for CANopen at all: CiA 402, the standardized profile for drives and motion control. CANopen's base object dictionary defines how devices exchange data, but says nothing about what a servo drive's states, commands, or operating modes should actually look like; without a standardized motion control profile, every drive vendor would define its own incompatible state machine and command set, forcing a control application to be rewritten for every different drive model. Embedded industrial motion control solutions built on CiA 402 avoid exactly that problem, giving any CiA 402-conformant drive from any vendor the same state machine and command interface a control application already knows how to drive.
Cia 402 motion control profile explained plainly: it's a CANopen device profile, standardized by CAN in Automation, that defines a state machine, standard object dictionary entries, and a set of operating modes specifically for drives, servos, and motion controllers. A CiA 402 device implements a well-defined sequence of states, Switch On Disabled, Ready to Switch On, Switched On, Operation Enabled, Fault, that a control application walks the drive through using standard control word bits, rather than a vendor-specific power-up and enable sequence that differs device to device. Because that state machine and its associated status and control word bit definitions are identical across every CiA 402-conformant drive, a control application written against the profile itself, rather than against one vendor's specific drive, can drive a replacement drive from a different manufacturer with minimal application-level rework.
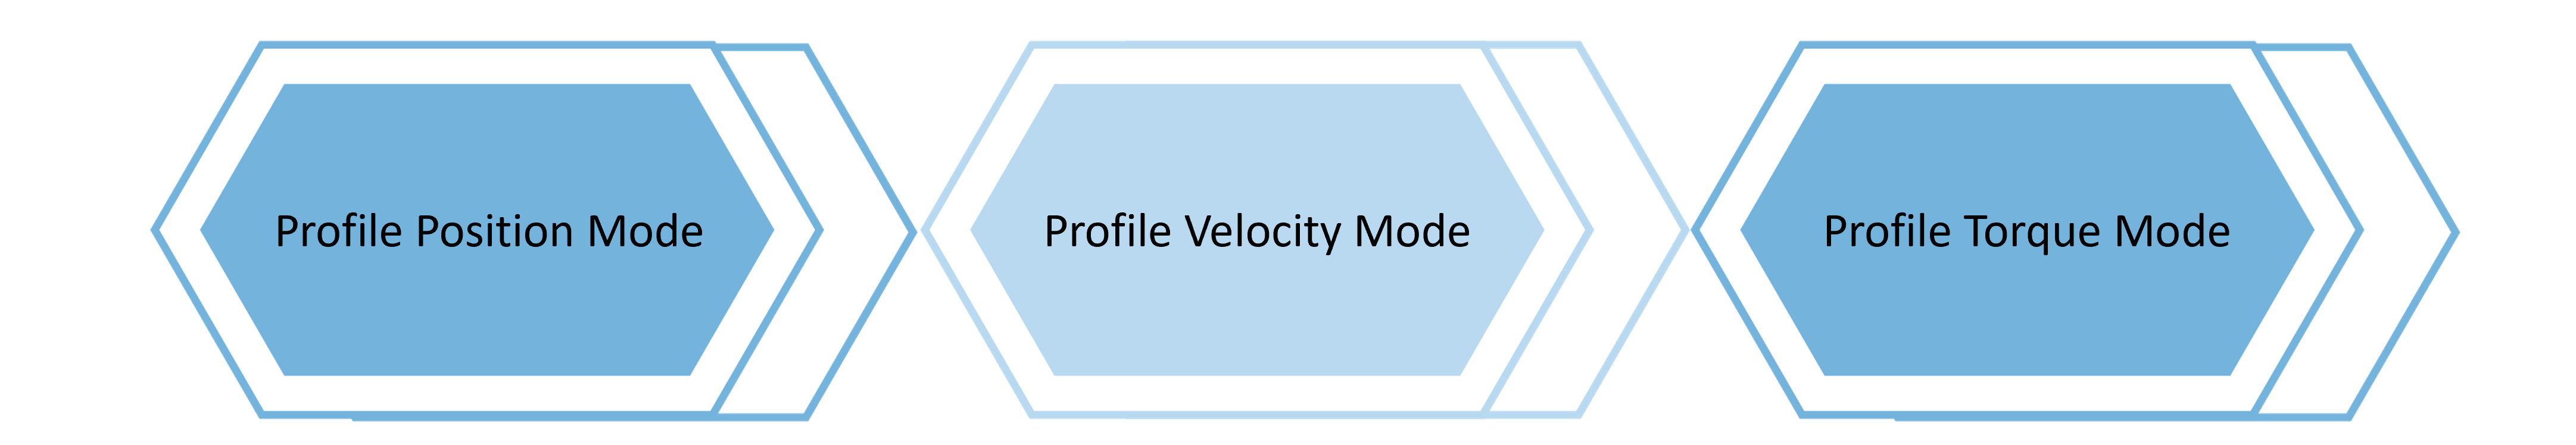
CiA 402 defines several standardized operating modes a drive can be commanded into, each suited to different application needs. Profile Position mode commands the drive to move to an absolute or relative target position along a defined velocity and acceleration profile, the drive's internal controller handling the trajectory. Profile Velocity mode commands a target speed directly, appropriate for continuous-motion applications like conveyor or spindle control rather than point-to-point positioning. Profile Torque mode commands a target torque or force output directly, used where the application needs to control applied force rather than position or speed, tensioning and pressing applications being common examples. A single CiA 402 drive frequently supports several of these modes, selectable through a standard object dictionary entry, letting one drive serve multiple control strategies without a firmware change.
Real-time motion commands and status, target position or velocity, actual position feedback, control word and status word, ride on CANopen's PDOs (Process Data Objects), the same cyclic, low-overhead communication mechanism CANopen uses generally, mapped specifically to CiA 402's standardized object dictionary entries for motion data. This is what makes CiA 402 practical for tight control loops: a control application writes a target position or velocity into a receive PDO and reads actual position and status back from a transmit PDO every network cycle, without the overhead of an SDO-based acyclic parameter exchange for data that needs to update on every control cycle. On a CoE-based EtherCAT network, covered in Embien's CANopen over EtherCAT article, this same PDO mapping model carries CiA 402 motion data at EtherCAT's much faster cyclic update rate.
Before a drive can execute accurate positioning commands, it typically needs to establish a known reference position, homing, and CiA 402 standardizes this too, through Homing Mode and a defined set of homing methods, using a limit switch, an index pulse, a hard mechanical stop, or a combination, selected via a standard object dictionary entry rather than vendor-specific homing logic. Standardizing homing methods across vendors means a control application's homing sequence logic, wait for homing complete status, handle a homing fault, doesn't need to be rewritten when a drive from a different manufacturer replaces an existing one, provided both implement the same CiA 402 homing method.
Programming drives and servos over canopen with cia 402 in practice means a control application's drive-interfacing code targets the profile's standard state machine, operating modes, and PDO layout rather than a specific vendor's drive firmware, which is precisely what makes CiA 402 the dominant real-world reason engineers reach for CANopen, or CoE on EtherCAT, in a Embien Technologies develops CANopen and CoE device stacks, including CiA 402 motion control profile implementations for servo drives and motion controllers, as part of our RAPIDSEA industrial communication suite. Our protocol engineering spans a device's classic CANopen implementation through CoE-based operation on EtherCAT, covered in Embien's CANopen over EtherCAT bridging article, giving drive and motion controller manufacturers a single CiA 402 implementation portable across both networks. To discuss embedded industrial motion control solutions built on the CiA 402 profile, reach out to Embien's engineering team.Embien's CANopen and Motion Control Protocol Engineering

Embien's product engineering services support industrial motion control product development, covering embedded hardware and firmware engineering, controller integration, CANopen communication, and system-level development for drives and connected industrial devices.

Embien's embedded software development services cover real-time firmware, device drivers, CANopen and EtherCAT protocol-stack integration, and CiA 402 device profile implementation for industrial servo drives, motion controllers, and automation equipment.
A case study demonstrating Embien's industrial communication engineering through the development of a protocol converter for wind turbine systems, highlighting embedded software, protocol translation, and integration between industrial equipment and monitoring networks.